SyncControl: Making Remote Steering Verifiable and Fail-Safe
A joint Interreg project of Smart-Ship and Seafar develops synchronised onboard control levers, an automatic emergency stop and a multi-thruster joystick, so that steering from shore can be shown to be safe.
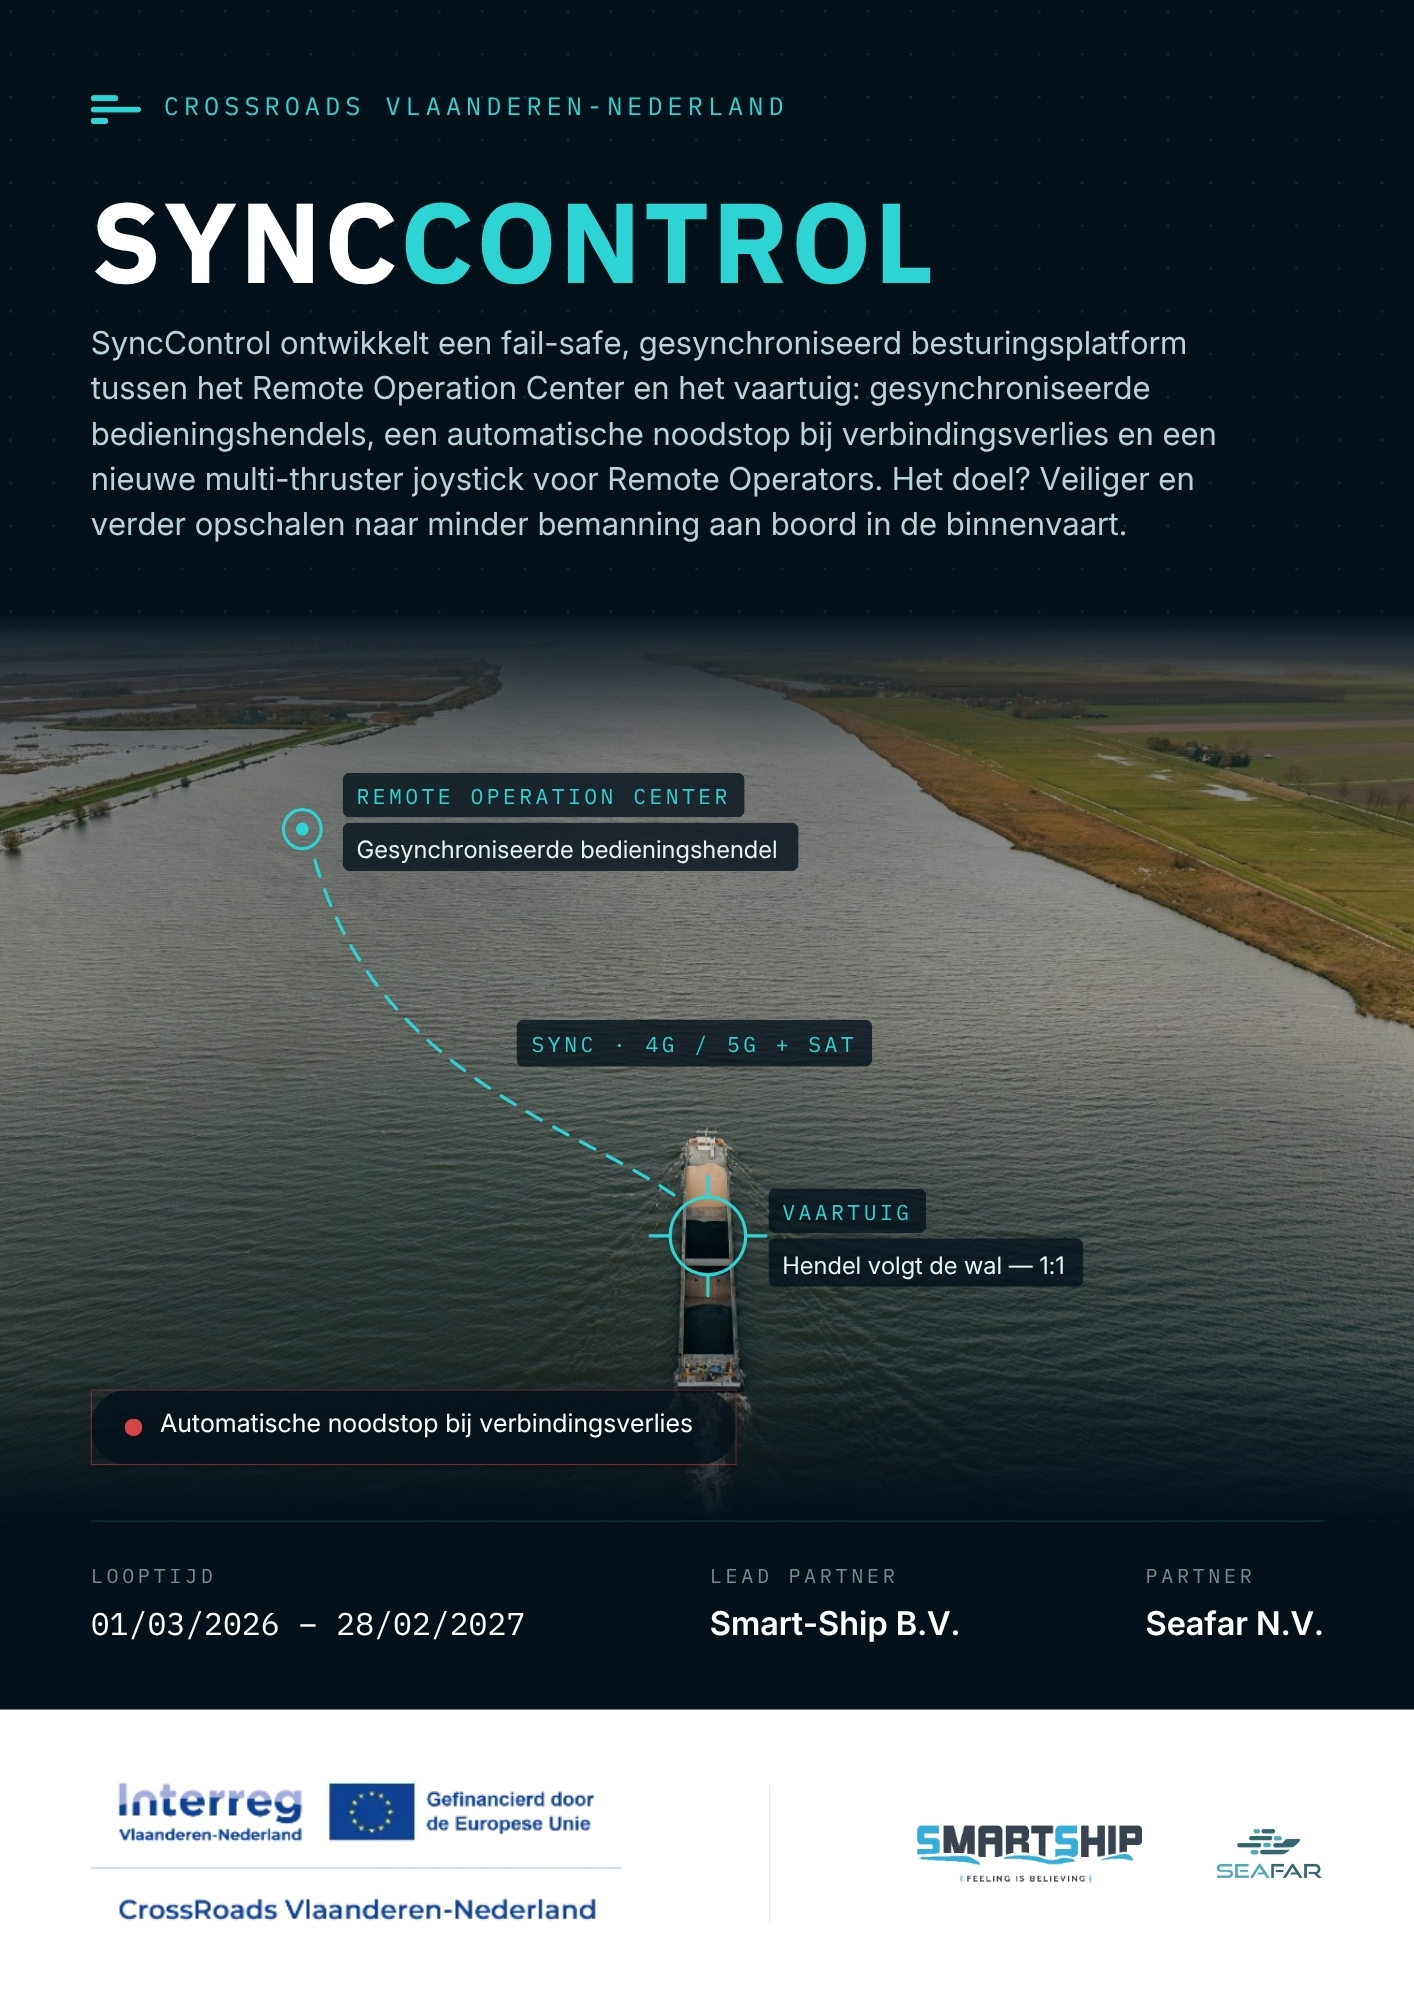
SyncControl is a joint research and development project of Smart-Ship and Seafar to make shore-based steering of inland vessels demonstrably safe. It runs from March 2026 to February 2027 and is co-financed by the European Regional Development Fund through CrossRoads Vlaanderen-Nederland, part of Interreg Vlaanderen-Nederland.
Project facts
- Programme
- CrossRoads Vlaanderen-Nederland, Interreg VI-A Vlaanderen-Nederland 2021-2027
- Funding
- European Regional Development Fund (ERDF)
- Duration
- 1 March 2026 to 28 February 2027
- Lead partner
- Smart-Ship B.V.
- Partners
- Seafar N.V.
- Demonstrator
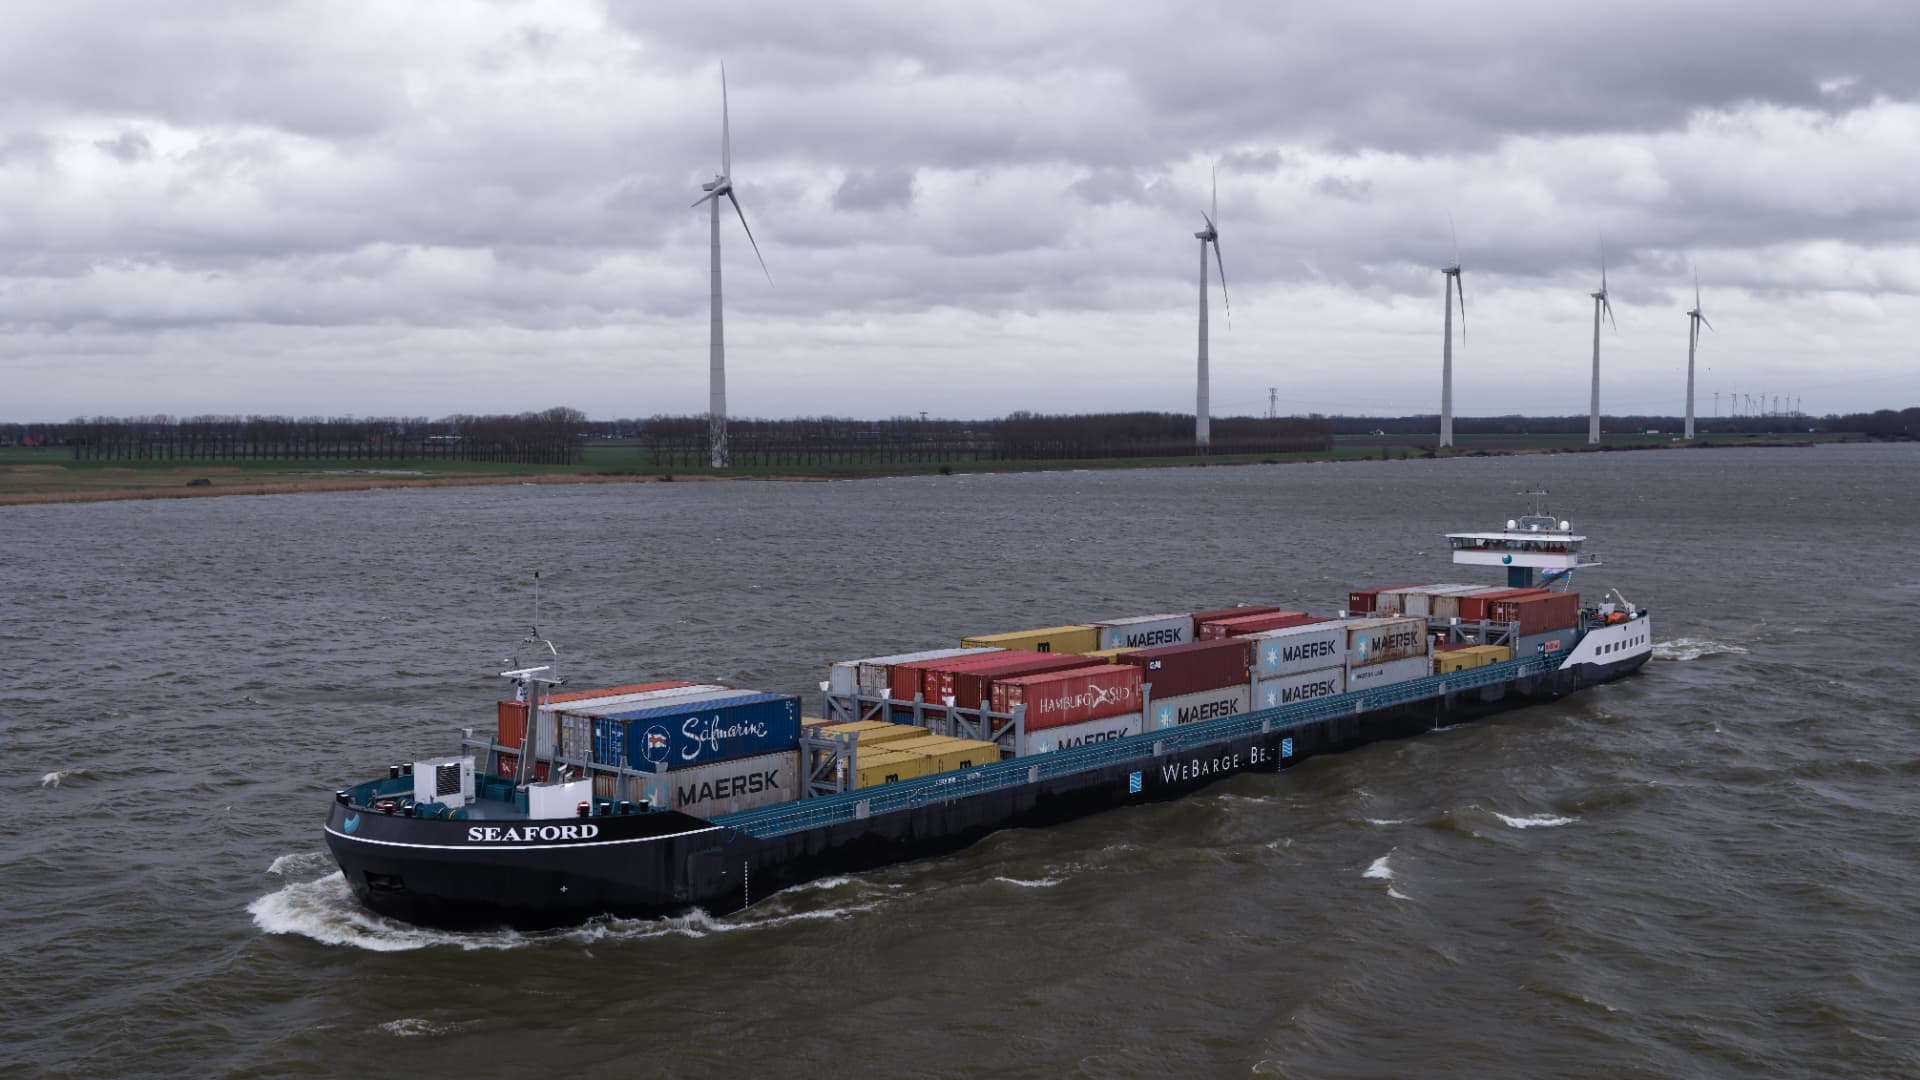
- Seafar's River Drone cargo vessel
- Status
- In progress
Why Remote Steering Has to Be Verifiable
Inland shipping is short of crew. The project plan expects the sector workforce to shrink by about 25 percent by 2030 compared with 2021, while transport volumes have to stay stable or grow.
Remote operations combined with haptic feedback already let existing customers sail with four crew instead of the traditional five. According to the project plan, fuel use and emissions at those customers are about 15 percent lower and downtime about 9 percent lower.
A wider roll-out is held back by regulators. They require that steering from the Remote Operation Center (ROC) stays verifiable and can be handed back safely on board at all times. SyncControl is built to answer that requirement.
What SyncControl Builds
The project develops one platform with three components.
Control levers on board mirror the steering input from the ROC in real time, so the boatmaster on board can see and verify what the Remote Operator commands.
If the connection between ROC and vessel is lost or degrades, the vessel is brought to a safe, controlled stop automatically.
A new joystick for Remote Operators replaces several separate levers with one intuitive control.
These figures are targets for the end of the project, not results. The platform starts at technology readiness level (TRL) 6 and is developed, integrated and validated up to TRL 8 on Seafar's River Drone.
Seafar's Role
SyncControl extends Seafar's Vehicle Control System (VCS) and Remote Operation Station (ROS) with a verifiable link to the controls on board and a fail-safe stop on connection loss. It supports Seafar's route towards smaller crews and wider regulatory acceptance of remote operations.
Who Does What
| Partner | Role |
|---|---|
| Smart-Ship B.V. (Delft, NL), lead partner | Haptic control hardware and software. Interface to the synchronised onboard levers, coupling to the propulsion, station-keeping on connection loss, and the multi-thruster joystick for the ROC, including control logic and force feedback. |
| Seafar N.V. (Antwerp, BE) | Remote operations. Shore-to-vessel data protocols and real-time synchronisation, connection-loss detection and fail-safe activation logic, preparation of the River Drone demonstrator and end-to-end testing against the acceptance criteria. |
Four Phases, March 2026 to February 2027
- 01Specification and Architecture (March to April 2026)
Requirements and end-to-end system architecture for steering from shore and on the vessel, joystick mapping, thruster control and fail-safe logic, plus the acceptance criteria.
- 02System Prototype (May to August 2026)
Interface prototypes with the onboard components, thruster-mixing and force-feedback algorithms, and scenario-based hardware-in-the-loop simulation.
- 03Installed Demonstrator (September to November 2026)
Installation and integration on the River Drone, and validation of the emergency stop under operational conditions.
- 04Operational Validation (December 2026 to February 2027)
Testing with experts, Remote Operators and boatmasters in normal sailing, docking, complex manoeuvres and connection-loss scenarios, ending in a report on compliance with regulations.
Where the Project Stands
According to the project plan, installation and integration on the River Drone run from September to November 2026, followed by operational validation. We add updates to this page as milestones are reached.
What Is Remote Vessel Operations in Inland Shipping?
How shore-based navigation works, how it differs from autonomous shipping and where it is permitted in Europe today.
Read the guideLiving Lab Green & Autonomous Corridor
Hydrogen-powered shipping and remote operation, tested aboard Samskip's SeaShuttles between Rotterdam and Oslo.
Read the projectFunding
SyncControl is part of CrossRoads Vlaanderen-Nederland and is co-financed by the European Regional Development Fund through Interreg Vlaanderen-Nederland.